[cid:36d6454a-27e0-4783-8845-fd9e01f726e0]
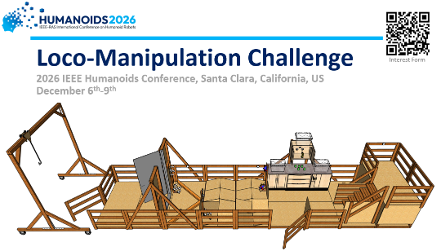
The 2026 IEEE/RAS Humanoids Conference in December will be hosting the Humanoid Loco-Manipulation Challenge. All humanoid research labs and industry teams are invited to participate. The competition is being organized by the National Institute of Standards and Technology (NIST), the same team that organizes the Legged Robot Challenge at ICRA and IROS. As humanoid robots move rapidly from research labs into real-world applications, reliable and comparable performance evaluation is more critical than ever. This competition will provide a repeatable, high-visibility environment to test your hardware and software against real-world tasks. Additionally, IEEE/RAS will also be offering travel grants to participating teams as needed and will be making multiple commercially-available humanoid robots available for teams to use on-site during the competition in order to lower the barrier of entry for teams developing their own control code. The competition rules, task descriptions, and other details can be found on the competition website: https://2026.ieee-humanoids.org/competitions/. Additional information such the build plans, CAD models, and simulation files for the competition testbed will be added, in case you want to build your own. If your team is interested, you can fill out this interest formhttps://forms.gle/prJqv2n9ej8d4JXs5 to stay up to date. Final registration via a submitted team description (required for travel support) will be due at end of October. Please send questions and other inquiries to the competition chairs at h**************c@ieee.orgmailto:h**************c@ieee.org.
Shelly Bagchi Collaborative Robotics Lab Project Leader, Performance of Emerging Technologies for Robotics (PETR) Intelligent Systems Division, Engineering Laboratory National Institute of Standards and Technology